Stuck on a step? Text us Email us Request a lesson
A matrix usually changes both the length and direction of a vector. An eigenvector is a nonzero input that stays on its own line through the origin. Its eigenvalue tells you how the matrix scales it, including whether the arrow reverses or collapses to zero.
By the end, you should be able to recognize an eigenvector geometrically, find eigenvalues and eigenspaces for a small matrix, and check every proposed answer in the original equation. You will work through two examples, compare repeated eigenvalues, then try five questions with optional hints and explained answers.
You should know matrix–vector multiplication, a two-by-two determinant and how to solve a homogeneous linear system. Revisit row operations and solution sets if needed. We use real matrices, real eigenvalues and real column vectors in this lesson; the last question explains why that choice matters.
1. What stays the same?
For a square matrix , a vector is an eigenvector with eigenvalue when
Here is matrix–vector multiplication and multiplies every component of the vector by the same real number. For example, is a column vector; its image under is another column vector.
- If , the output points the same way as the input.
- If , the output points the opposite way, along the same line.
- If , the output is the zero vector, which has no direction. The input can still be an eigenvector.
The length is multiplied by . It grows when , shrinks when , and is unchanged when . Thus “preserves direction” needs care: the line is preserved, but the arrow can reverse, and a zero output has no arrow direction.
For the diagonal matrix below, the horizontal and vertical axes are eigendirections:
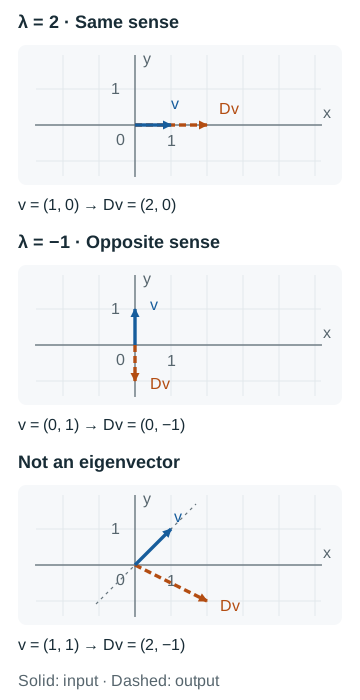
Indeed, . No single multiplier changes both input components to those outputs, so this vector is not an eigenvector.
If is an eigenvector, every nonzero multiple is one too, with the same eigenvalue, because . An eigenvector therefore need not be a unit vector, and there is usually no single preferred length.
2. Find the number, then the vectors
Rearrange the eigenvector equation using the identity matrix , which leaves a vector unchanged:
For an -by- matrix, this homogeneous system has a nonzero solution exactly when is singular, meaning it is not invertible. The determinant detects that condition:
This is the characteristic equation. It finds eigenvalues, not eigenvectors. Subtract only from the diagonal entries. In two dimensions,
gives
- Find the eigenvalues. Solve the characteristic equation.
- Find the vectors for each value. Substitute that value into , then solve the system. Keep the free parameters.
- Separate the space from its eigenvectors. The solution set is the eigenspace. The kernel means all vectors sent to zero by that matrix. The eigenspace includes zero; its nonzero vectors are the eigenvectors.
- Check in the original matrix. Compute and independently. All components must agree, and must be nonzero.
3. Worked example: two eigendirections
Find all eigenvalues and eigenvectors of
Find the two eigenvalues
Setting this to zero gives and .
Solve the system for each eigenvalue
For ,
Both equations say , so
For ,
Now both equations say , so
Each eigenspace is a line through the origin. To list its eigenvectors, require . The parameter can be positive or negative.
Check one nonzero vector on each line
Linearity extends each check to every scalar multiple on that line. These are all eigenvectors, because the characteristic equation has no other roots and each associated system has been solved completely.
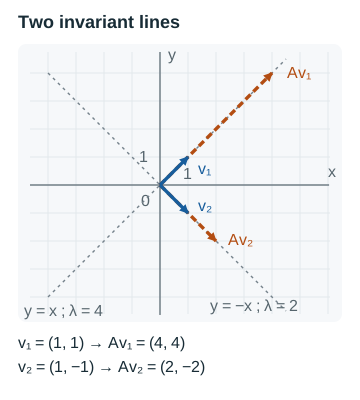
The vector is not on either line. Its image is not a scalar multiple of it. Two eigendirections do not make every vector an eigenvector.
4. Worked example: a zero eigenvalue
Projection onto the horizontal axis is represented by
The characteristic equation is , so the eigenvalues are and .
- For , solve . It gives : every nonzero horizontal vector stays unchanged.
- For , solve . It gives : every nonzero vertical vector collapses to the origin.
For example,
The input is nonzero, so it qualifies. The zero output has no direction; we do not call it an eigenvector. More generally, zero is an eigenvalue of a square matrix exactly when the matrix is singular. Its eigenspace for eigenvalue zero is its kernel.
Projection does not make every input an eigenvector: , which is not a multiple of the input.
5. What a repeated eigenvalue does not tell you
In the plane, two nonzero vectors are linearly independent when neither is a scalar multiple of the other. A basis of a space is a set of independent vectors whose scalar multiples can be added to produce every vector in that space, uniquely. One nonzero vector forms a basis of a line; two independent vectors form a basis of the plane. Their dimensions are one and two, respectively.
Compare
Both have characteristic equation . The root occurs twice, so its algebraic multiplicity is two. That does not tell you how many independent eigenvectors exist.
- For , the system gives . Its eigenspace is one line, with basis .
- For , the matrix is zero. Every real vector solves the system, so its eigenspace is the whole plane. Every nonzero vector is an eigenvector.
The dimension of an eigenspace is the eigenvalue’s geometric multiplicity: one for , two for . There are infinitely many eigenvectors in each case; the difference is the maximum number of linearly independent eigenvectors you can choose from that eigenspace. You must solve the system to find it.
Diagonalization means choosing a basis in which the same linear map has a diagonal matrix. A two-by-two real matrix can be diagonalized over the real numbers exactly when it has two linearly independent real eigenvectors. Thus cannot be diagonalized, while is already diagonal. A repeated eigenvalue alone settles neither outcome.
6. Five questions to try
Keep the answers closed at first. Start with direct checks, then find a complete eigenspace, diagnose a misleading shortcut and try a rotation. The hints are separate from the answers.
Question 1: one multiplier for the whole vector
For , decide which inputs below are eigenvectors. For each one that qualifies, give its eigenvalue.
Show a hint for question 1
Compute every output. A negative component in the input does not by itself make the eigenvalue negative. Exclude the zero input before comparing vectors.
Show the answer and reasoning for question 1
, so has eigenvalue . Also , so has eigenvalue ; the output points the same way as this downward input.
For , the output is . The first component would require multiplier , the second , so there is no eigenvalue for that input. The vector is excluded by definition.
Question 2: find and check both eigenspaces
Find all eigenvalues and eigenvectors of . Explain why the second coordinate axis is not an eigendirection, even though the matrix is triangular.
Show a hint for question 2
The determinant is the product of the diagonal entries of . For each root, solve both equations and retain a free parameter.
Show the answer and reasoning for question 2
, so the eigenvalues are and . For , the system gives . For , it gives , hence .
All eigenvectors are for eigenvalue , or for eigenvalue , with . Direct checks give and .
But , which leaves the vertical axis. For a triangular matrix, the diagonal entries are its eigenvalues; the coordinate vectors need not all be eigenvectors.
Question 3: can a whole plane collapse?
For the two-by-two zero matrix , find all eigenvalues and eigenvectors. Is its zero-eigenspace just the zero vector?
Show a hint for question 3
For a nonzero input, solve . Then distinguish the full solution space from the allowed eigenvectors.
Show the answer and reasoning for question 3
Every input maps to zero. Since , the equation forces , the only eigenvalue. Its eigenspace is all of , and its eigenvectors are all nonzero real two-component vectors. The eigenspace includes zero, but the eigenvector list does not. Here the root has algebraic and geometric multiplicity two.
Question 4: two vectors or two independent directions?
A student finds the repeated eigenvalue for from section 5 and proposes and as “two independent eigenvectors.” Check the vectors and correct the conclusion about diagonalization.
Show a hint for question 4
Both vectors can pass the eigenvector equation while failing a different requirement. Can one be made by scaling the other?
Show the answer and reasoning for question 4
Both are eigenvectors with eigenvalue , but the second is twice the first. They are linearly dependent. Since forces , every eigenvector lies on this same line. No second independent eigenvector exists, so cannot be diagonalized. Choosing another length cannot create another independent direction.
Question 5: a rotation with no real eigendirection
The matrix rotates the plane by a quarter-turn counterclockwise. Does it have a real eigenvalue? Explain with both its characteristic equation and its geometry.
Show a hint for question 5
Find . A nonzero arrow rotated by a quarter-turn cannot stay on its original line.
Show the answer and reasoning for question 5
, which is positive for every real . There are no real roots, so there are no real eigenvalues or real eigenvectors. Geometrically, every nonzero arrow turns onto a perpendicular line; none collapses to zero. Over the complex numbers the roots are and , where , but complex eigenvectors are outside the real-plane picture used here.
7. Check your reasoning and choose a next step
- Can you say what the sign and magnitude of an eigenvalue do to a nonzero input?
- Did you subtract the eigenvalue only on the diagonal and solve the resulting homogeneous system?
- Did you give the full eigenspace, then exclude zero when listing eigenvectors?
- Did you verify each representative using the original matrix, rather than only the determinant?
- For a repeated root, did you count independent vectors by solving the system?
If the multiplication or free parameters caused difficulty, return to matrix and vector fundamentals. If the computations worked, explain the contrast between and without looking at section 5, then use your course materials to continue to change of basis and diagonalization.
For wider course context, see the guides for Concordia MATH 204 and McGill MATH 133.
Course context and further reading
This original lesson supports the eigenvalue and eigenvector topics in MATH 204 at Concordia and MATH 133 at McGill. Use your own course outline for the scope assigned to you. The links below establish topic relevance and provide further explanation.
Useful for
Work on the step you’re missing.
Tell us the subject and your preferred time. Nablio confirms the details by text or email.
Request a lesson