Return to Sheridan MATH15382D course guide. Tutoring coverage for this course must be confirmed before booking and payment.
From a right triangle to a full turn
You already know sine and cosine as side-length ratios in a right triangle. Here we extend them to any rotation, including negative angles and several turns. Review right-triangle lengths and angles if choosing opposite and adjacent sides is still difficult.
You will need fractions, square roots, coordinates and simple equations. Allow about 45 minutes for the lesson and a first practice pass. This is focused preparation, not a claim to cover a whole course. Angles are in radians unless a degree symbol is shown. Put your calculator in radian mode.
The Greek letter names an angle. A point has horizontal coordinate and vertical coordinate . Positive rotation is counterclockwise from the positive horizontal axis; negative rotation is clockwise. The horizontal variable in a graph will be labelled explicitly: an angle and a time are different quantities.
1. Radians measure arc length per radius
For a circle of radius , an arc of length subtends an angle with magnitude . Use matching length units. The sign comes from the direction of rotation; ordinary arc length is nonnegative. A full circumference is , so one positive turn is radians, or . Thus radians.
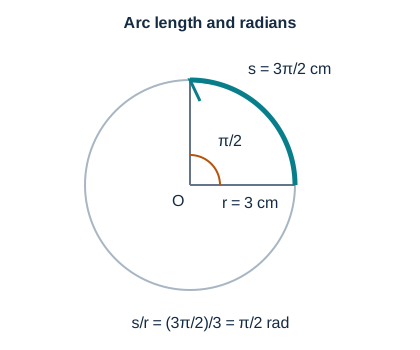
Worked example 1: keep the direction
A wheel of radius 4 cm turns clockwise through an arc length of 6 cm. Find the signed angle.
This is about . Dividing two lengths cancels their units; “rad” identifies the angle convention. The angle is not radians: the radius matters. Adding a full turn gives the same final direction: , but describes a different rotation.
2. Coordinates, signs and exact values
The unit circle is centred at the origin and has radius 1. At angle , define
In the first quadrant, dropping a perpendicular gives a right triangle with hypotenuse 1, so these definitions agree with the side ratios. In other quadrants, coordinates carry signs; triangle lengths do not. In quadrants I, II, III, IV, the signs of are respectively . Axis points lie on quadrant boundaries.
For a point off the axes, its reference angle is the acute angle to the nearest horizontal half-axis. In one positive turn, the four positions associated with are . Use the quadrant to restore signs.
A 45°–45°–90° triangle gives . Bisecting an equilateral triangle gives , , and swaps these values at .
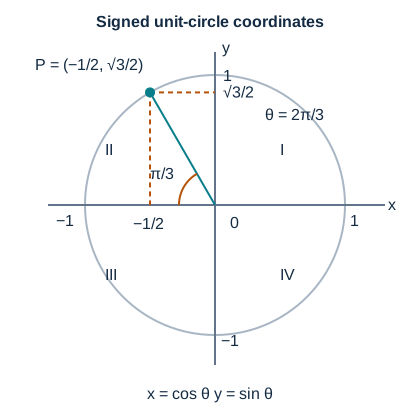
Worked example 2: reduce, locate, then sign
Find and exactly. The angle is in quadrant IV, with reference angle . Therefore
Check: . The coterminal angle reaches the same point. At axis angles, read the coordinates directly: gives , gives , and returns to . Also only when ; tangent is undefined at for every integer .
3. Describe directions and add displacements
A displacement vector records a change in position, with a magnitude and a direction. Its signed horizontal and vertical components describe that same change along two perpendicular axes.
Worked example 3: a displacement vector
A robot moves 8 m in a straight line at angle , measured counterclockwise from east. Take east as positive horizontal and north as positive vertical. Scaling the unit-circle coordinates by the length gives
The displacement is 4 m west and m north. These are signed components, not two additional trips. Check the length: m. This coordinate method describes direction without introducing any force model.
Add a second leg on the same axes
Call that first displacement . The robot then moves 8 m east, so its second displacement is . Keep east positive and north positive for both vectors. Draw the second arrow from the tip of the first. The resultant is the arrow from the original start to the final position.
Add horizontal components to horizontal components and vertical components to vertical components, preserving their signs:
Thus : 4 m east and m north overall.
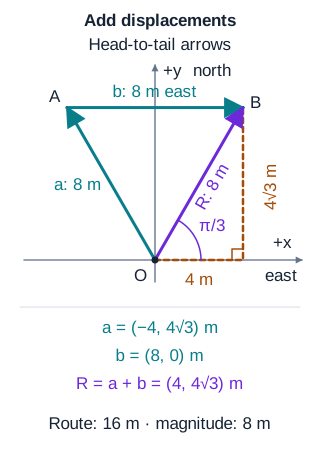
Recover magnitude and direction
The resultant’s horizontal and vertical components are perpendicular, so Pythagoras gives its magnitude :
Both components are positive, placing the resultant in quadrant I. Dividing its components by its magnitude gives
Hence , measured counterclockwise from east, or 60° north of east. The robot travelled , while its start-to-finish displacement has magnitude 8 m. Do not use for the two travelled legs: those legs are not perpendicular. Add their signed components first, then use the resultant’s right triangle.
Your tutor can help you choose axes, draw the arrows, explain a negative component and work through a changed route with you. Try question 11 with a shorter second leg.
Ready to apply components to forces? Find a net force and the acceleration it produces.
4. Trace sine and cosine from a rotating point
Let the angle increase steadily. Plotting the point’s height against angle traces ; plotting its horizontal coordinate against angle traces . In these graphs, the horizontal axis is the angle in radians, not the point’s horizontal position.
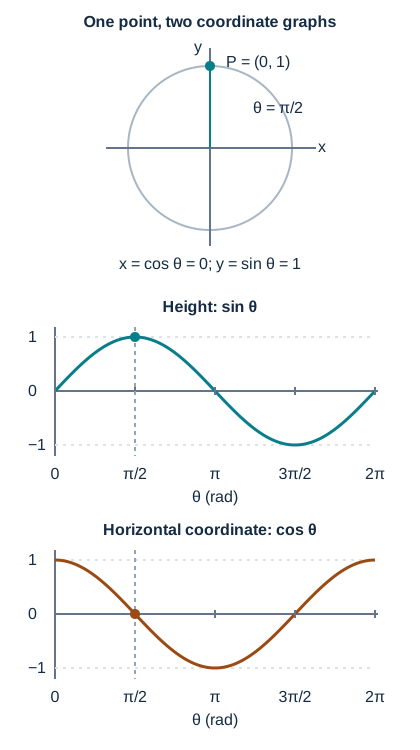
Both graphs repeat after . Sine starts at 0 and initially increases; cosine starts at 1. Their ranges are . Since opposite rotations preserve the horizontal coordinate and reverse the vertical one, and . These identities also check signs for negative angles.
5. Amplitude, period and horizontal shift
For a sinusoidal model
assume and . The same features apply with sine in place of cosine.
- is the midline; amplitude is , the absolute value of , or its distance from zero. It is always nonnegative.
- The range is . A negative reflects the graph about its midline.
- The period is , because the angle must increase by .
- is a horizontal shift: positive means right, negative means left. Factor the coefficient of before reading it.
If is in seconds, is in radians per second, and in seconds, and use the same output unit. If the input is an angle , the period and shift instead describe changes in angle. When or , the model is constant and has no least positive period; the usual nonconstant-sinusoid description does not apply.
Worked example 4: interpret a periodic height
An ideal marker’s height in centimetres is modelled by
where is the numerical time in seconds. The midline is 7 cm, amplitude 3 cm, range cm, period s and shift 1 s right. At , the angle is zero, so cm, a maximum. At , the angle is , so cm, a minimum. Expanding the angle gives ; the shift is still 1 s, not s.
This ideal model repeats without damping. A time trace of one point on a sinusoidal wave uses the same graph idea. In waves in space and time, distinguish this period in seconds from a wavelength measured along a spatial axis; this lesson does not model the travelling wave itself.
6. Find every solution on the stated interval
An inverse trigonometric function returns one principal angle, not automatically every solution. In radians, returns a value in , in , and in . Real arcsine and arccosine require . The notation on a calculator means arcsine, not the reciprocal .
Worked example 5: find all solutions, including endpoints
Solve for . The calculator gives the principal answer , which is outside the requested interval. Sine is negative in quadrants III and IV. The reference angle is , giving
Both substitute to . Neither endpoint works: . Over all real angles, add to each solution, where is any integer; then keep only values in the requested interval.
Boundary check: on has two angle values, 0 and , even though they represent the same circle point. On , exclude . At extrema, do not count the same angle twice: has only in one turn. A request such as has no real solution.
For a transformed graph, first isolate the sine or cosine, solve for its entire angle, and then recover the original variable. Translate the interval too, or check each recovered value against the original interval.
Eight graduated practice questions
Try each question before opening its hint. Check the quadrant, unit and interval in every answer.
Convert and to radians.
Optional hint 1
Multiply each degree measure by .
Explained solution 1
, and . The negative sign preserves clockwise rotation.
A circle has radius 5 cm. Find the arc length for a counterclockwise angle .
Optional hint 2
Use , with the angle in radians.
Explained solution 2
cm. This is an arc length, not a chord. It is positive because this arc has nonzero length.
Find the unit-circle coordinates at .
Optional hint 3
Locate the quadrant and subtract to get the reference angle.
Explained solution 3
The reference angle is in quadrant III, so both coordinates are negative: . Their squares sum to 1.
Find , , and explain whether exists.
Optional hint 4
Reflect the positive angle across the horizontal axis; tangent needs nonzero cosine.
Explained solution 4
and . At , the circle point is , so tangent would divide by zero and is undefined.
A unit-circle point rotates from to . State the sine and cosine values at , and say which graph decreases throughout this half-turn.
Optional hint 5
Read the coordinates of the right, top and left points.
Explained solution 5
Sine has values ; cosine has values . Cosine decreases throughout the half-turn. Sine first increases, then decreases; matching endpoints alone would miss its peak.
For , with in seconds and in centimetres, find amplitude, midline, period, shift and range.
Optional hint 6
Write . The amplitude uses an absolute value.
Explained solution 6
Amplitude 4 cm; midline 2 cm; period s; shift 1 s left; range cm. The coefficient −4 reflects the sine curve about the midline; it does not make the amplitude negative.
Solve on . Compare with the principal arccosine answer.
Optional hint 7
Cosine is negative in quadrants II and III.
Explained solution 7
The reference angle is , giving . The principal answer supplies only the first. Neither endpoint has cosine .
Solve on , then on .
Optional hint 8
Zeros of sine occur at integer multiples of ; inspect the brackets.
Explained solution 8
The closed interval includes . The half-open interval includes only . Although and reach the same circle point, they are distinct angle values and each is kept when its endpoint is included.
Three transfer and retry questions
A 12 m displacement has horizontal component m and vertical component m. Find its direction in , measured counterclockwise from the positive horizontal axis.
Optional hint 9
Divide each component by 12; find a reference angle and then its quadrant.
Explained solution 9
, . Both are negative, so the direction lies in quadrant III with reference angle . Thus , or . Using only would lose the quadrant. The length check is m.
For the height model , find every time when cm for s.
Optional hint 10
Isolate cosine. Its zeros are . Recover before filtering the interval.
Explained solution 10
gives . Therefore , so seconds. The allowed integers give s. Both endpoints count. Substitution makes the cosine zero at each time. The midline is crossed twice per 4 s period, with the shared interval boundaries counted only once each.
Changed-data retry: keep the robot’s first 8 m displacement at from east, but change the second leg to 4 m east. Find the resultant’s signed components, magnitude and direction in . Also find the total distance travelled.
Optional hint 11
Keep the same axes. Add and . If the horizontal components cancel, read the remaining axis direction directly.
Explained solution 11
Thus , with magnitude . Since and , the vector points due north: . Read the positive vertical axis; would divide by zero. The distance travelled is . The shorter eastward leg cancels the first leg’s westward component without changing its northward component.
Before moving on, explain why a principal angle is not always enough, why amplitude is nonnegative, and why interval endpoints can change the answer. If a step remains difficult, retry the matching question with a circle sketch or explicit units.
Optional extension: prove trigonometric identities
Prove an identity, rather than find an angle
An identity says that two expressions have equal values for every input in their common domain. The domain matters: an expression with a zero denominator is undefined, even if a later simplified expression has a value there.
By contrast, solving an equation asks which allowed inputs make it true. For example, holds for every real angle . The equation holds only at particular angles. Here is a real angle; use radians when an interval is stated. The notation means .
Start with these known facts:
- , for every real .
- , where .
- , where .
A useful proof starts with one side and transforms it into the other using justified equalities. State restrictions first; rewrite tangent or secant using sine and cosine; then use common denominators, factoring or the Pythagorean identity. Checking a numerical angle can expose an error, but cannot prove a claim for every angle.
Identity example 1: rewrite before cancelling
Prove on its domain.
The original left side requires . For these angles,
.
The cancelled factor is nonzero because of the original restriction. At , the right side equals 1 but the original left side is undefined. The identity therefore does not give a value to that left side at .
Identity example 2: use a common denominator
Prove .
Both sides require . Transform the left side:
.
The number 1 was rewritten as ; it did not disappear. This is an identity on , not an equation whose task is to find .
Identity example 3: factor while keeping the original domain
Simplify , and explain where the result agrees with .
The original denominator requires . Factor the numerator:
, provided .
At , the original quotient is and undefined. The simplified expression has value 2, but this does not remove the original restriction. We have equivalent values on the original domain, not identical domains for the two formulas.
Practise in four steps
Open the hint or solution whenever it helps. You do not need to finish a question before asking for help.
Prove . State the domain.
Optional hint 12
Replace the numerator before cancelling.
Explained solution 12
Require . The numerator equals , so the quotient is on that domain.
Prove . State the domain and explain how the second term joins the fraction.
Optional hint 13
Rewrite tangent; give both terms denominator .
Explained solution 13
Require . The left side becomes . Multiplying by preserves its value on the allowed domain.
Simplify . Is the original expression defined at ?
Optional hint 14
Factor as a difference of squares and retain the denominator restriction.
Explained solution 14
Require . Factoring gives . At the original denominator is zero, so the original expression is undefined. The value 2 from the simplified formula is not a value of the original quotient there.
On , solve . Explain why this task is different from Identity example 1.
Optional hint 15
First retain the domain of tangent, then use Identity example 1.
Explained solution 15
The original equation requires . On this domain it becomes , giving or in the stated interval. Both have nonzero cosine and satisfy the original equation. Identity example 1 established an equality for every allowed angle; this equation selects the angles at which the common value is .
A tutor can help you identify the permitted angles, choose a useful first transformation and explain why each step preserves the expression. We can begin with the basic identities or an unstarted question.
For domain restrictions, inverse functions and graph shifts beyond sine and cosine, continue with functions, transformations and inverses.
For help with a unit-circle or trigonometric-graph problem, explore algebra and precalculus tutoring. Tutoring sessions are currently offered in English.
Useful for
Focused practice for functions and trigonometry in Concordia MATH 201 and Dawson 201-015-RE, and a foundation review for Sheridan MATH15382D. These lessons cover selected topics, not a complete course; use your current section’s outline for assessment scope.
Work on the step you’re missing.
Tell us the subject and your preferred time. Nablio confirms the details by text or email.
Request a lesson